Part of ggSkyGrid · See the connected roadmap →
ggGridRunner
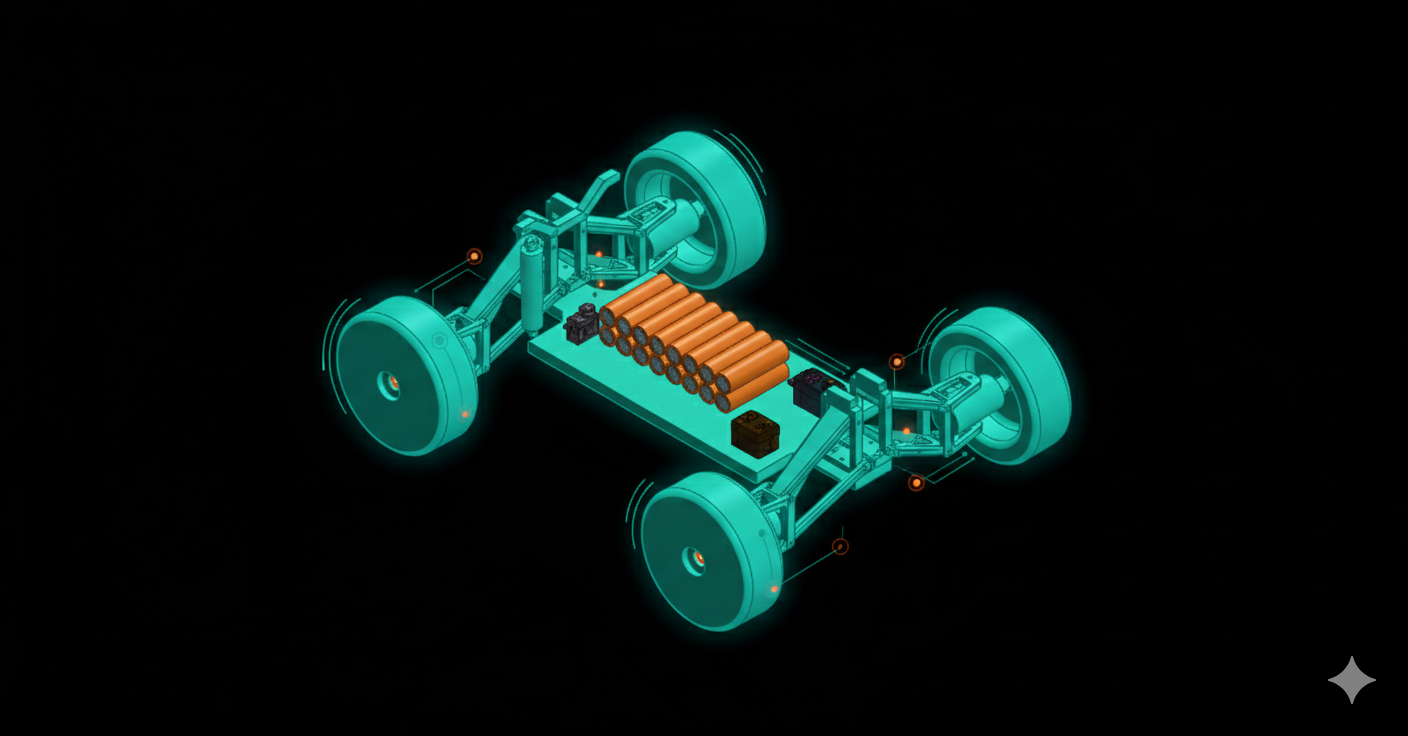
A 4-wheel-steering ground rover: where I learn embedded hardware and firmware before anything flies.
Objective
Build an STM32 rover driven by a PS4 controller over XBee radios, with a safe, checksummed remote link, then heading hold.
Project Overview
A ground rover with four independently steered wheels (Ackermann, crab and spin-in-place modes). An STM32 Blue Pill runs the rover; an Arduino Pro Micro reads a PS4 controller and talks to it over XBee radios. It is the first rung of my drone projects: learn firmware, IMU drift, motor control and a failsafe radio link where a mistake doesn’t crash.
Roadmap & Development Phases
Motors spin
STM32 flashed; motors run forward and reverse with correct throttle scaling, wheels in the air.
Safe remote link
PS4 → XBee → motors, with framed, CRC-checked packets and a dead-man's switch.
Chassis build
Suspension designed, printed and assembled, in parallel with the bench milestones.
Drives on remote
Electronics in the chassis, driven around on the remote.
Heading hold
Encoders plus IMU hold a straight line.
Technical Approach
- Compute: STM32 Blue Pill on the rover, Arduino Pro Micro in the remote, linked by XBee radios
- Input: PS4 controller for manual driving
- Drive: four driven wheels, each steered by its own servo (motor driver still being chosen)
- Chassis: 3D-printed custom frame
- Software: C++ firmware for motor control and wireless command parsing
Connection to GG Swarm
Like ggSkybit, my hobby drone, this rover is a stepping stone toward real-world autonomous coordination. The plan is to apply navigation and consensus algorithms developed in simulation to physical ground-based platforms.
Project Log
No log entries found for this project.